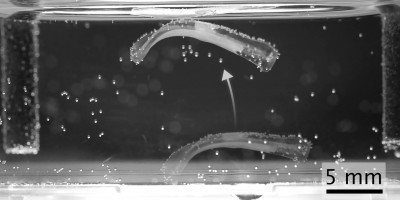
A five-millimetre jump shows why robot muscle and scaffold must be designed together
ETH’s biohybrid actuators gain movement through co-designed tissue and structure. Nutrient supply and biological variability still keep them in the lab.
ETH’s biohybrid actuators gain movement through co-designed tissue and structure. Nutrient supply and biological variability still keep them in the lab.
The researchers combine a large language model with experimental checks. A generated sequence and a useful biological function remain different claims.